
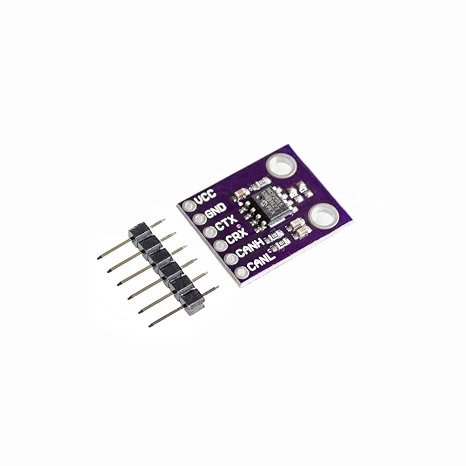
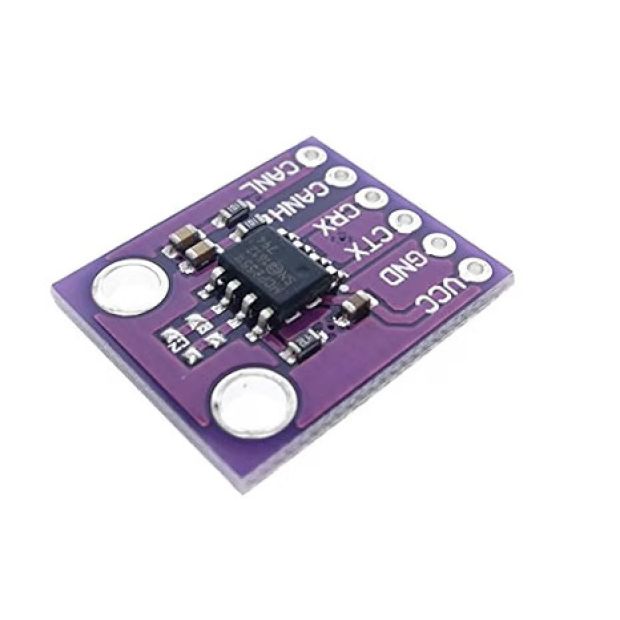
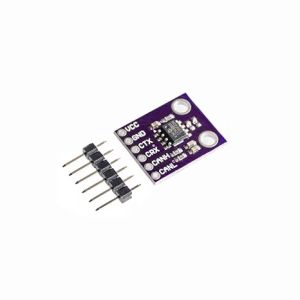
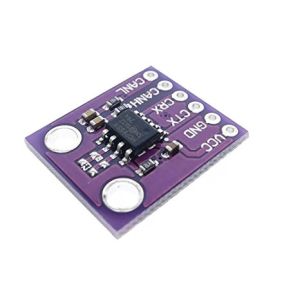
CJMCU-2551 MCP2551 High-Speed CAN Bus Transceiver Interface Module
Bridge your microcontrollers to industrial and automotive CAN networks seamlessly with the CJMCU-2551 MCP2551 High-Speed CAN Transceiver Module. Operating at 5V, this compact board converts digital TX/RX signals from a CAN protocol controller into differential CAN bus levels. Supporting high-speed data rates up to 1 Mb/s with robust EMI shielding, it ensures highly reliable, noise-immune communication for vehicle diagnostics and industrial automation.
₹ 87
₹ 139
| : |
The Electroboat CJMCU-2551 MCP2551 High-Speed CAN Protocol Controller Interface Module is a fault-tolerant, high-speed CAN transceiver that serves as the interface between a CAN protocol controller and the physical bus. Designed to meet the stringent requirements of the ISO-11898 standard, this module provides differential transmit and receive capabilities for microcontrollers operating in noisy electrical environments.
Whether you are building custom OBD-II automotive diagnostic scanners, linking multiple Arduino/ESP32 nodes across long distances, or designing industrial robotic control systems, the MCP2551 IC guarantees data integrity. It features advanced short-circuit protection, thermal shutdown, and protection against high-voltage transients on the CAN bus lines, making it incredibly resilient in real-world automotive and industrial conditions.
Key Features and Benefits
-
High-Speed Communication: Supports reliable data transmission rates of up to 1 Mb/s for real-time control systems.
-
ISO-11898 Compliant: Fully meets the physical layer requirements for 12V and 24V automotive systems.
-
High Node Capacity: Allows up to 112 independent nodes to be connected on a single CAN network.
-
Robust Fault Protection: Built-in protection against battery shorts, ground faults, and high-voltage electrical transients.
-
Low RF Emission (EMI): Slope control on the output drivers reduces electromagnetic interference, ensuring clean signal integrity.
Technical Specifications
How to Use
-
Power the Module: Connect the
VCCpin to a clean 5V DC supply and theGNDpin to your microcontroller's ground. -
Logic Connection: Connect the
TXDandRXDpins to the corresponding Transmit and Receive pins of your CAN controller IC (e.g., MCP2515) or a microcontroller with a built-in CAN peripheral (like STM32 or ESP32). -
Bus Connection: Wire the
CANHandCANLpins to the high and low lines of your physical CAN network. -
Termination Resistor: Ensure your CAN bus network is properly terminated with a 120-ohm resistor at both ends of the physical bus line to prevent signal reflection.
Applications
-
Automotive OBD-II Diagnostics & ECU Communication
-
Industrial Factory Automation & Sensor Networks
-
Marine & Aerospace CAN Bus Systems
-
Multi-Node Arduino, STM32, and Raspberry Pi Communication
-
Advanced Robotics & Motor Driver Synchronization
Package Includes
-
1 x CJMCU-2551 MCP2551 CAN Protocol Controller High-speed Interface Module
-
1 x Straight Male Header Pin Strip
Shipping & Delivery
-
Free shipping on orders above ₹999 across India.
-
Dispatched within 1-3 business days.
-
Expected delivery: 3-7 business days depending on location.
-
Secure ESD and cushioned packaging to ensure safe transit of electronic components.
0 Reviews For this Product
Related Products